Projects
Government-, defense-, and industry-funded research projects.
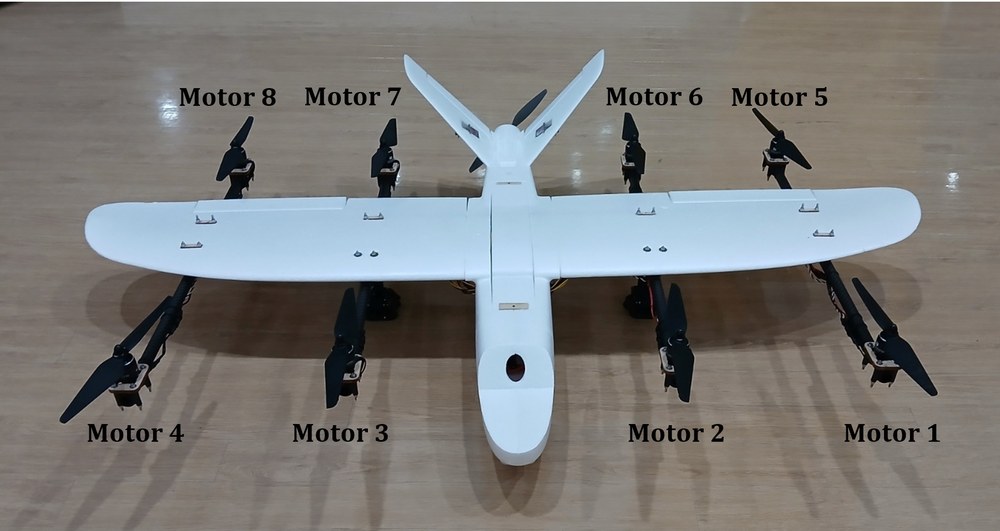
AI-based fault detection, isolation, and reconfiguration for eVTOL and distributed-electric-propulsion aircraft.
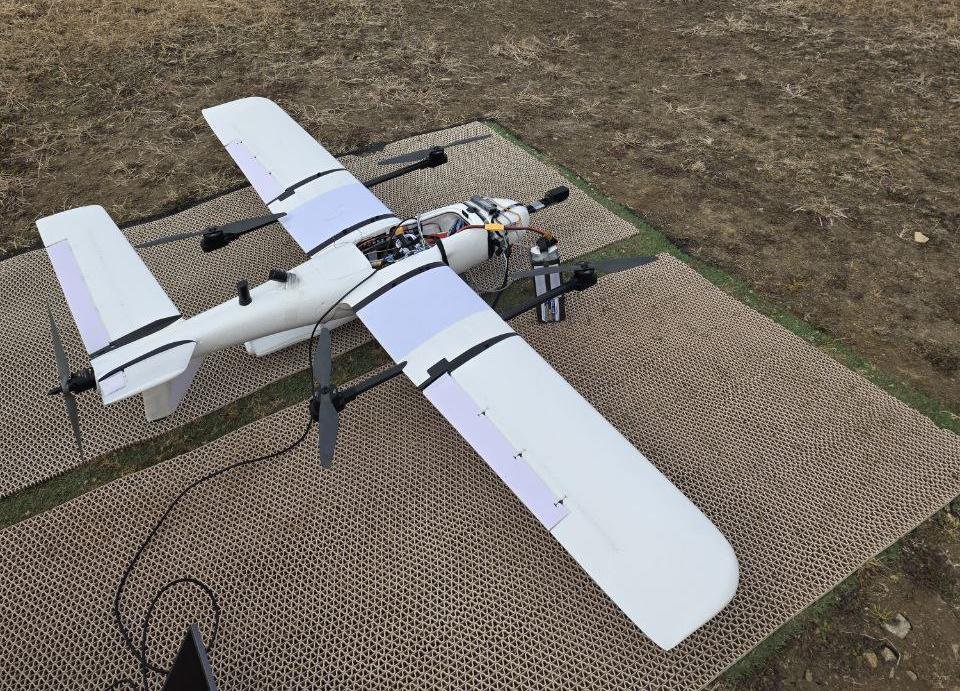
Quantum-magnetometer-aided navigation for GNSS-denied operation across aerial, marine, and ground vehicles.
Rover navigation algorithms using quantum-magnetometer-aided navigation.
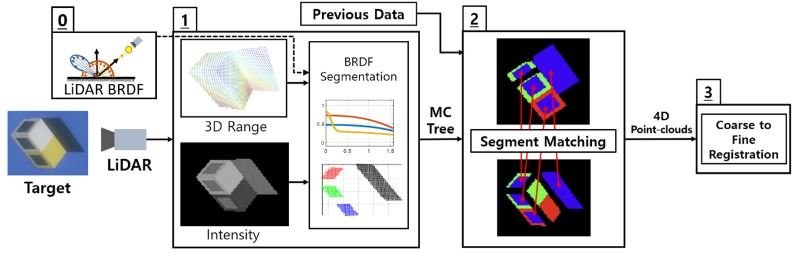
Optical-sensor-based navigation for autonomous spacecraft operation.
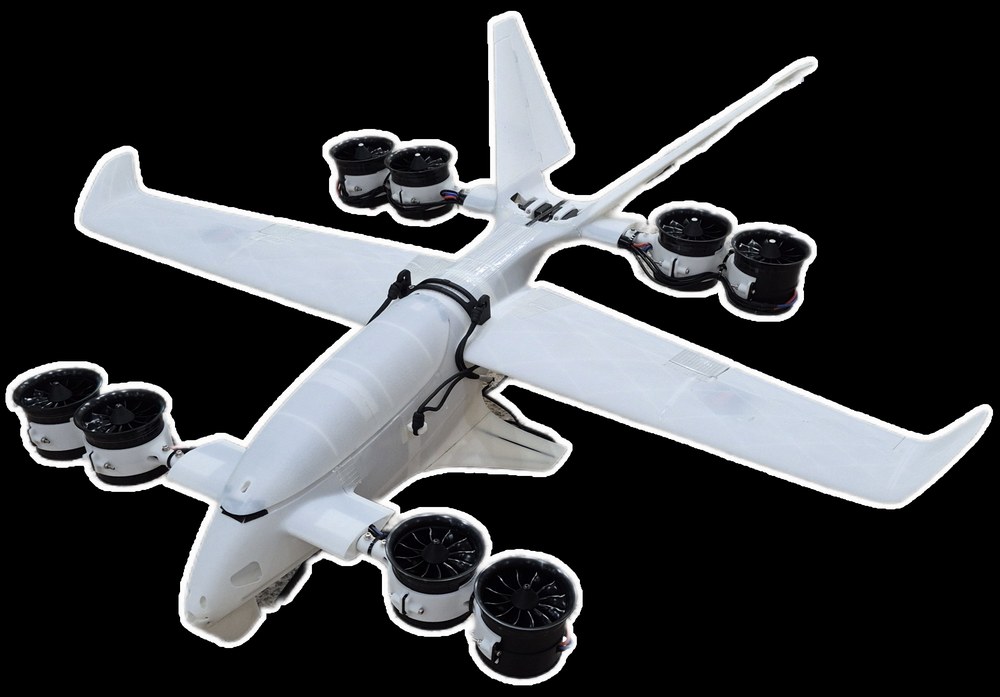
Flight control, fault diagnosis, and fault-tolerant control under motor and rotor loss of effectiveness.
RF-satellite roadmap and RF-signal-based algorithms for maritime vessel identification.
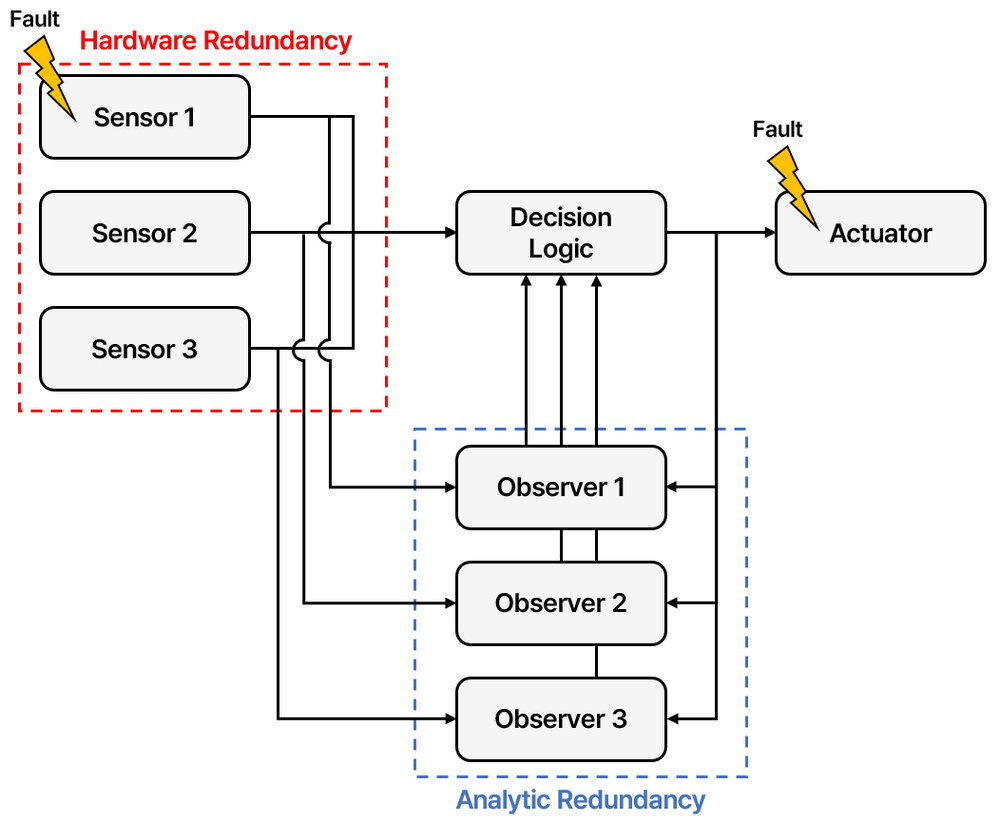
Flight control computer hardware, redundancy schemes, and fault detection algorithms.
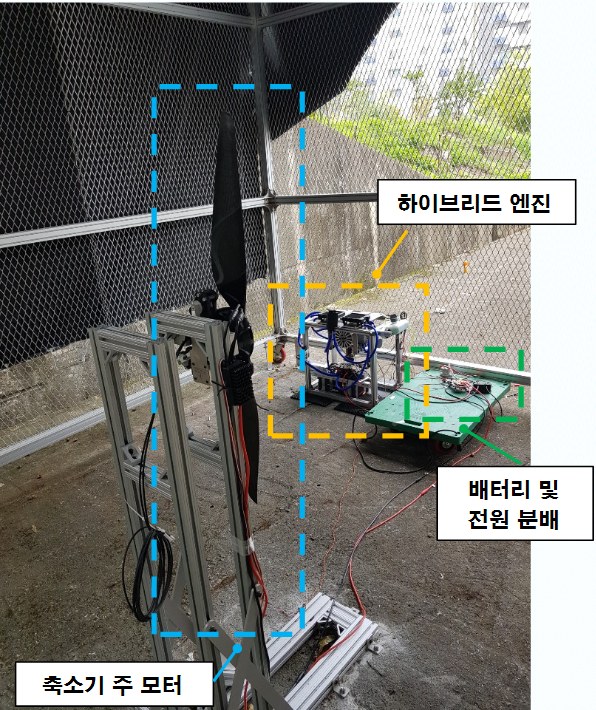
Hybrid-electric powertrain modeling and UAM conceptual sizing (EUCASS 2022).
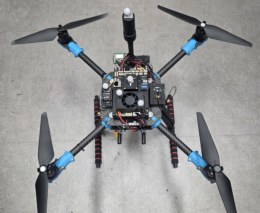
Nonlinear attitude and altitude control and a small-drone platform; led to the KIMST 2025 Best Paper Award on MPC/NDO terrain following.
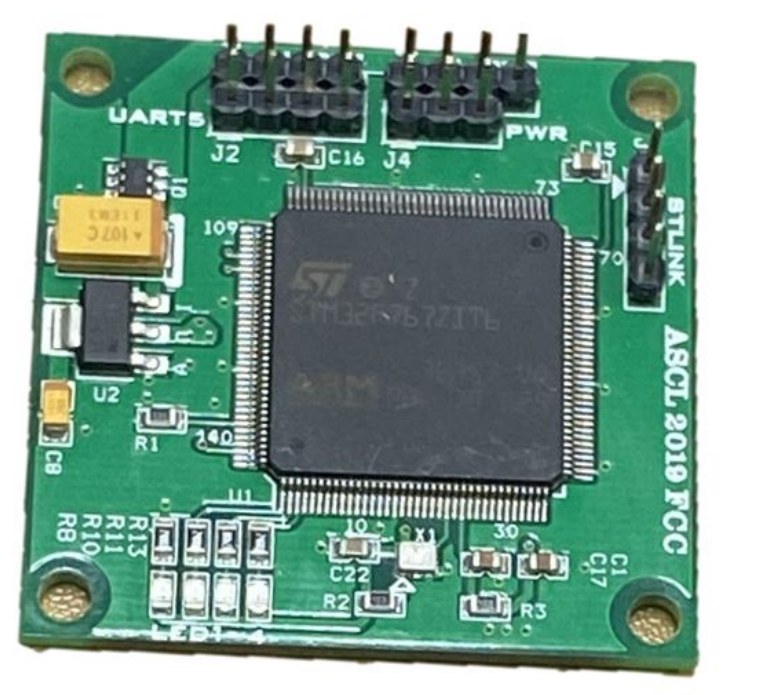
Core project of my Ph.D.: compact flight control computers, redundancy and voting, and fault-detection pipelines for UAVs.
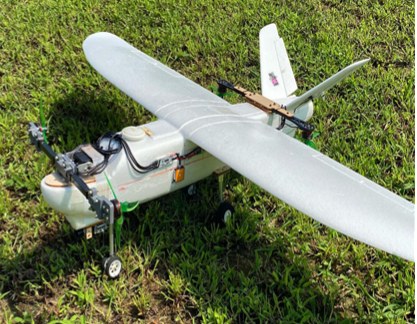
Nonlinear adaptive control, a tilt-rotor prototype, and a HILS environment.
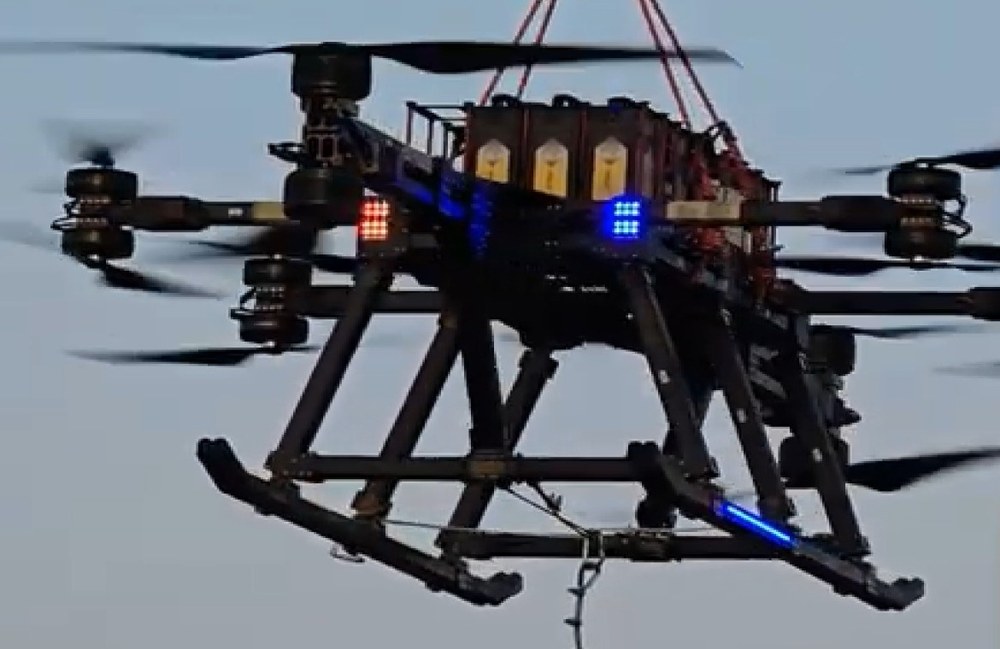
Airframe configuration design, system identification, and GNC/autonomous flight integration for a VTOL hoverbike.