Research
Advanced GNC technologies for future air mobility.
My research develops guidance, navigation, and control (GNC) methods that keep aerial vehicles safe under model uncertainty, component faults, and loss of GNSS, and validates them on real flight hardware. It is organized into three fundamental areas and two future directions.
1 · AI-based guidance & control
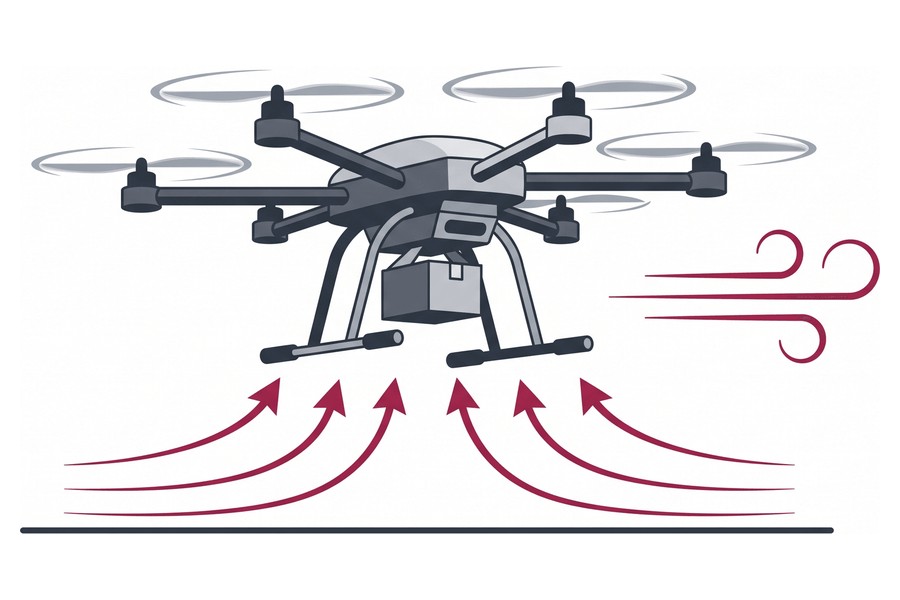
Unmodeled forces in normal flight
GP regression · SINDy · disturbance observers · MPC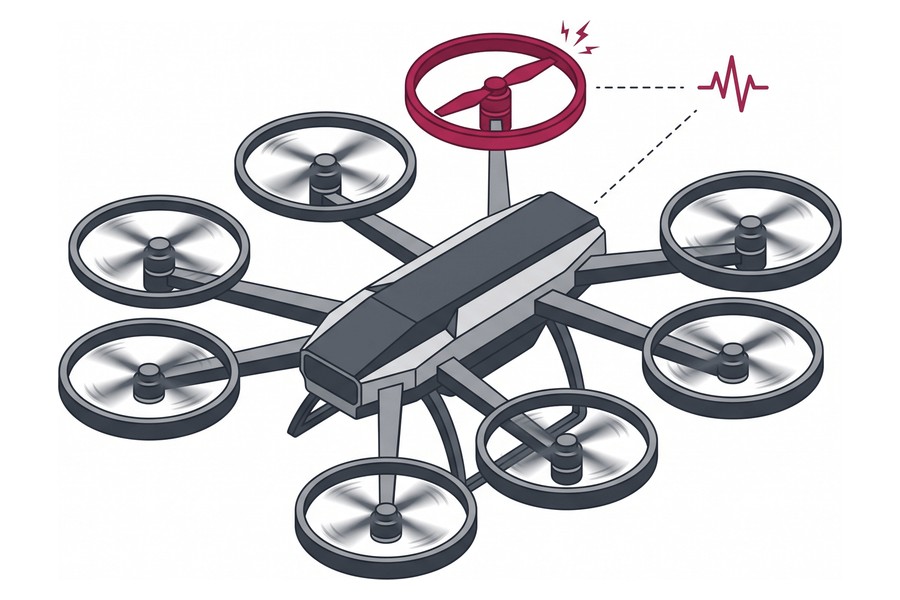
2 · Fault diagnosis & fault-tolerant control
Internal faults: actuators and sensors
Koopman operator · residuals · detect–isolate–reconfigure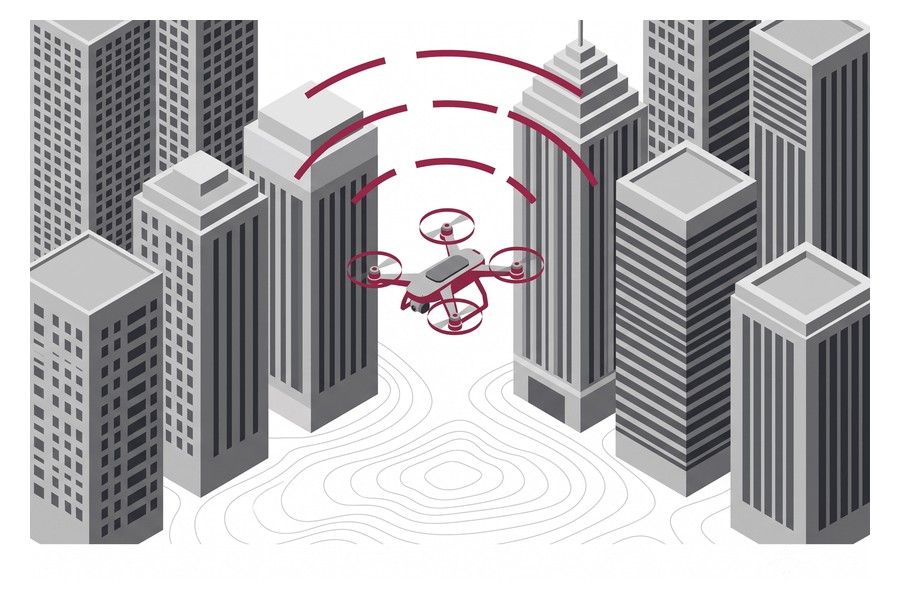
3 · GNSS-denied navigation
External disruption: GNSS jammed or lost
Quantum magnetometer · map matching · factor graphs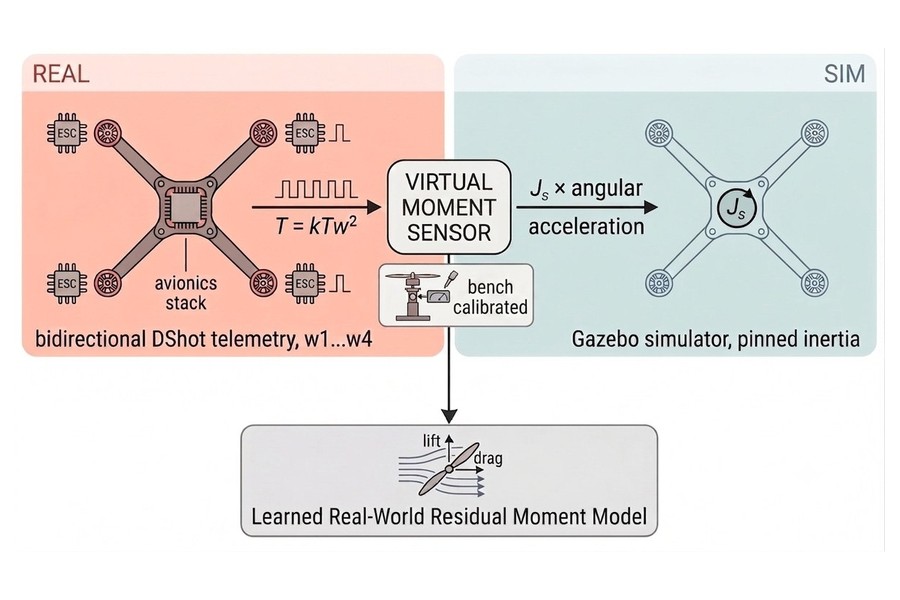
4 · Digital twin & integrated validation
Repeat fault injection and GNSS loss in the twin
Virtual moment sensor · physics–residual hybrid twin · HILS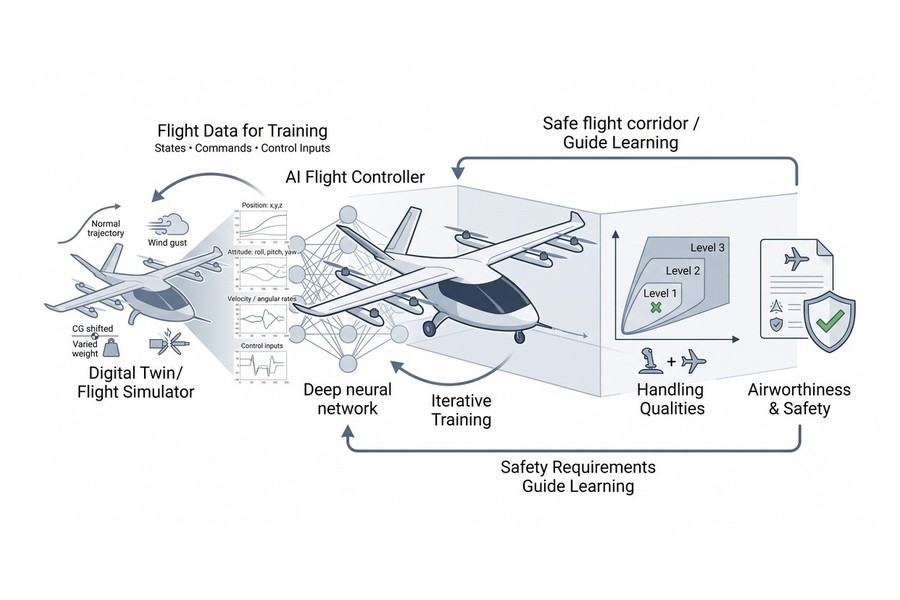
5 · Certifiable AI flight control
Learning-based control that meets certification requirements
Handling qualities · run-time assurance · requirement-driven RLFundamentals
1 · AI-based guidance & control
I learn vehicle dynamics from data with Gaussian processes, SINDy, and reinforcement learning, and use the learned models inside adaptive, incremental, and model-predictive controllers. The aim is a controller that adapts to the vehicle it actually flies, including ground effect, payload changes, and aerodynamic uncertainty.
- Sparse online GP-based robust NDI with ground effect (AST 2025)
- SINDy-based MPC for collision avoidance (IET CTA 2025)
- GP-based state derivative estimator for INDI (AST 2024)
- RL-based error-gated σ-modification adaptive autopilot (IJCAS, accepted)
- Guided exploration RL for 3D pursuit-evasion (IJCAS 2025)
2 · Fault diagnosis & fault-tolerant control
For multirotors, eVTOL, and UAM, I develop methods that detect, isolate, and accommodate actuator and sensor faults in real time. This includes data-driven fault diagnosis with SINDy and Koopman-operator models, kernel-based fault detection, and fault-tolerant control allocation for over-actuated airframes.
3 · GNSS-denied navigation
When satellite navigation is jammed or unavailable, I estimate vehicle position with factor graph optimization, combining INS with UWB, terrain, and quantum magnetometer measurements of the magnetic anomaly field. This work connects estimation theory to quantum sensing hardware for passive navigation.
Future directions
4 · Digital twin & integrated validation
I build digital twins that are updated with flight data, together with hardware-in-the-loop test benches and custom redundant flight control computers, so that an algorithm can move from simulation to flight with the same software.
5 · Certifiable AI flight control
Learning-based controllers need to satisfy the same requirements as conventional ones before they can fly in certified aircraft. I study handling-qualities requirements (e.g., MIL-STD-1797, ADS-33) as design constraints, run-time assurance that switches between AI and classical controllers, and requirement-driven reinforcement learning.
Videos of these experiments are on the home page.
For the full record, see my publications and funded projects.