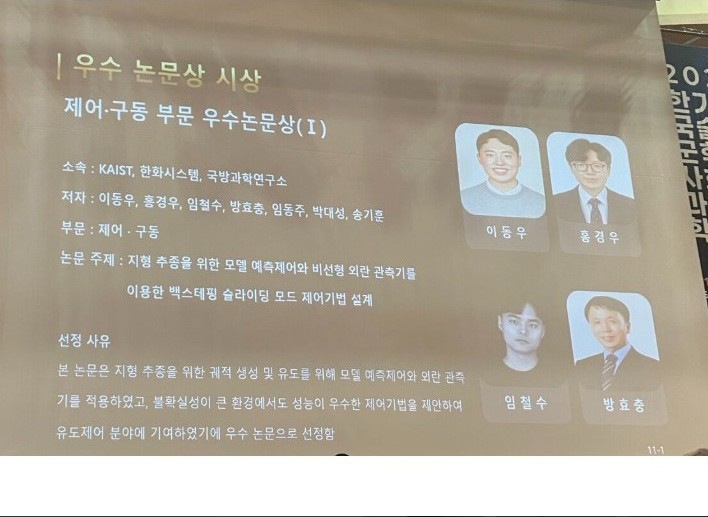
Best Paper Award at the KIMST 2025 Conference
Our paper A Design of Model Predictive Control and Nonlinear Disturbance Observer-based Backstepping Sliding Mode Control for Terrain Following received the Best Paper Award (control and actuation) at the 2025 Korea Institute of Military Science and Technology conference.